 LeRobot
SO-101 table top MuJoCo
Tabletop view
READY
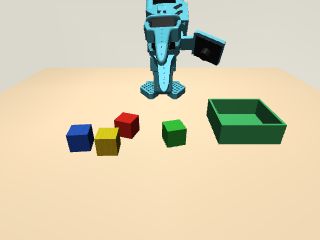
CAM 01 FRONT
Click the view to focus keyboard controls— FPS
Joints
How to run it?
Requires a LeRobot source checkout with Space EnvHub support and Docker with the NVIDIA Container Toolkit.
lerobot-env-server \
  --envhub=lerobot/so101-tabletop-mujoco \
  --trust_remote_code=true --docker=true